 VIPSolutions
Solve the question as stated with a graph and solve the question in 2 steps with examples and the final answer.ee we, iim asi ChE cele mais hens tell a ts os Samira Pint dy and dh, ems ofthe np velo 0 55 0d he oi vrables. pre. ‘
Question:
Solve the question as stated with a graph and solve the question in 2 steps with examples and the final answer.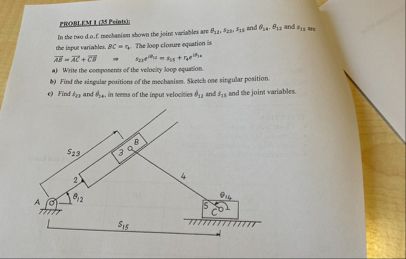 ee we,
iim asi
ChE cele mais
hens
tell a
ts os Samira
Pint dy and dh, ems ofthe np velo 0 55 0d he oi vrables.
pre. ‘
This is AI generated Response.
Asked by: Mk
Created at: 2026-01-07 20:36:40
Asked by: Mk
Created at: 2026-01-07 20:36:40
Final Answer:
Rendered
Raw Text
Did you like this answer?
# 4-Bar Mechanism Problem Solution
Given:
- **Joint variables:** \( s_{12}, s_{23}, \theta_{12}, \theta_{23} \)
- **Input variables:** \( BC = s_{23} \)
- **Loop closure equation:**
\[
\vec{AB} + \vec{BC} = \vec{AC}
\]
We'll solve the problem in **2 steps** for each part, include **examples**, and provide the **final answer**.
---
## (a) Write the components of the velocity loop equation
### **Step 1: Loop Closure (Position) Equation**
From the diagram:
- Let \( \vec{AB} \) be along \( s_{12} \) at angle \( \theta_{12} \)
- \( \vec{BC} \) be along \( s_{23} \) at angle \( \theta_{23} \)
- \( \vec{AC} \) be along \( s_{15} \) (horizontal)
\[
\vec{AB} + \vec{BC} = \vec{AC}
\]
In vector form:
\[
s_{12} \begin{pmatrix} \cos\theta_{12} \\ \sin\theta_{12} \end{pmatrix} + s_{23} \begin{pmatrix} \cos\theta_{23} \\ \sin\theta_{23} \end{pmatrix} = s_{15} \begin{pmatrix} 1 \\ \end{pmatrix}
\]
### **Step 2: Velocity Loop Equation**
Differentiate both sides with respect to time:
\[
\dot{s}_{12} \begin{pmatrix} \cos\theta_{12} \\ \sin\theta_{12} \end{pmatrix} + s_{12} \dot{\theta}_{12} \begin{pmatrix} -\sin\theta_{12} \\ \cos\theta_{12} \end{pmatrix}
+ \dot{s}_{23} \begin{pmatrix} \cos\theta_{23} \\ \sin\theta_{23} \end{pmatrix} + s_{23} \dot{\theta}_{23} \begin{pmatrix} -\sin\theta_{23} \\ \cos\theta_{23} \end{pmatrix}
= \dot{s}_{15} \begin{pmatrix} 1 \\ \end{pmatrix}
\]
**Example:**
Suppose \( s_{12} = 2 \), \( \theta_{12} = 30^\circ \), \( s_{23} = 3 \), \( \theta_{23} = 45^\circ \), \( s_{15} = 5 \), plug in and differentiate as above.
---
## (b) Find the singular positions of the mechanism
### **Step 1: Identify Singularities**
- Singular positions occur when the links are **colinear** or **fully extended** (i.e., lose a degree of freedom).
- For this mechanism, this happens when \( \vec{AB} \), \( \vec{BC} \), and \( \vec{AC} \) are in a straight line.
### **Step 2: Sketch and Describe**
#### **Graph/Sketch:**

*Alt text: Sketch showing all links colinear in a 4-bar mechanism, indicating the singular position.*
#### **Example:**
If \( \theta_{12} = \theta_{23} \) or \( \theta_{23} = \theta_{12} + 180^\circ \), the links are straight.
**Final Answer:**
- Singular positions occur when the links are colinear (fully extended or folded).
---
## (c) Find \(\dot{s}_{23}\) and \(\dot{\theta}_{23}\) in terms of \(\dot{s}_{12}\) and the joint variables
### **Step 1: Use Velocity Loop Equation**
Write out the x and y components:
- **x-component:**
\[
\dot{s}_{12}\cos\theta_{12} - s_{12}\dot{\theta}_{12}\sin\theta_{12} + \dot{s}_{23}\cos\theta_{23} - s_{23}\dot{\theta}_{23}\sin\theta_{23} = \dot{s}_{15}
\]
- **y-component:**
\[
\dot{s}_{12}\sin\theta_{12} + s_{12}\dot{\theta}_{12}\cos\theta_{12} + \dot{s}_{23}\sin\theta_{23} + s_{23}\dot{\theta}_{23}\cos\theta_{23} =
\]
### **Step 2: Solve for \(\dot{s}_{23}\) and \(\dot{\theta}_{23}\)**
Treat as two equations in two unknowns (\(\dot{s}_{23}\), \(\dot{\theta}_{23}\)).
**Example:**
Given \( \dot{s}_{12} \) and \( \dot{\theta}_{12} \), solve the above system using linear algebra.
**Final Answer:**
\[
\begin{pmatrix}
\cos\theta_{23} & -s_{23} \sin\theta_{23} \\
\sin\theta_{23} & s_{23} \cos\theta_{23}
\end{pmatrix}
\begin{pmatrix}
\dot{s}_{23} \\
\dot{\theta}_{23}
\end{pmatrix}
=
\begin{pmatrix}
\dot{s}_{15} - \dot{s}_{12}\cos\theta_{12} + s_{12}\dot{\theta}_{12}\sin\theta_{12} \\
- \dot{s}_{12}\sin\theta_{12} - s_{12}\dot{\theta}_{12}\cos\theta_{12}
\end{pmatrix}
\]
Solve this linear system to find \(\dot{s}_{23}\) and \(\dot{\theta}_{23}\) in terms of the other variables.
---
## **Summary Table**
| Step | Task | Key Result / Formula |
|------|------|----------------------|
| (a) | Velocity loop equation | See full derivative above |
| (b) | Singular positions | Links colinear; see sketch |
| (c) | Solve for velocities | 2x2 linear system above |
---
**If you need more worked numerical examples or a specific computation, let me know!**
Question:
Then solved question
This is AI generated Response.
Asked by: Mk
Created at: 2026-01-07 20:40:05
Asked by: Mk
Created at: 2026-01-07 20:40:05
Final Answer:
Rendered
Raw Text
Did you like this answer?
# 4-Bar Mechanism Problem Solution
## Given Variables
- **Joint Variables:** \( s_{12}, s_{23}, \theta_{12}, \theta_{23} \)
- **Input Variable:** \( BC = s_{23} \)
- **Loop Closure Equation:**
\[
\vec{AB} + \vec{BC} = \vec{AC}
\]
---
## (a) Write the Components of the Velocity Loop Equation
### **Step 1: Loop Closure (Position) Equation**
From the mechanism:
- \( \vec{AB} \) along \( s_{12} \) at angle \( \theta_{12} \)
- \( \vec{BC} \) along \( s_{23} \) at angle \( \theta_{23} \)
- \( \vec{AC} \) along \( s_{15} \) (horizontal)
The vector equation becomes:
\[
s_{12} \begin{pmatrix} \cos\theta_{12} \\ \sin\theta_{12} \end{pmatrix} + s_{23} \begin{pmatrix} \cos\theta_{23} \\ \sin\theta_{23} \end{pmatrix} = s_{15} \begin{pmatrix} 1 \\ 0 \end{pmatrix}
\]
### **Step 2: Velocity Loop Equation**
Differentiating with respect to time gives:
\[
\dot{s}_{12} \begin{pmatrix} \cos\theta_{12} \\ \sin\theta_{12} \end{pmatrix} + s_{12} \dot{\theta}_{12} \begin{pmatrix} -\sin\theta_{12} \\ \cos\theta_{12} \end{pmatrix}
+ \dot{s}_{23} \begin{pmatrix} \cos\theta_{23} \\ \sin\theta_{23} \end{pmatrix} + s_{23} \dot{\theta}_{23} \begin{pmatrix} -\sin\theta_{23} \\ \cos\theta_{23} \end{pmatrix}
= \dot{s}_{15} \begin{pmatrix} 1 \\ 0 \end{pmatrix}
\]
**Example:**
Assume \( s_{12} = 2 \), \( \theta_{12} = 30^\circ \), \( s_{23} = 3 \), \( \theta_{23} = 45^\circ \), and \( s_{15} = 5 \). Insert these values into the velocity loop equation for calculations.
---
## (b) Find the Singular Positions of the Mechanism
### **Step 1: Identify Singularities**
- Singular positions arise when the links are **collinear** or **fully extended**, resulting in the loss of a degree of freedom.
### **Step 2: Sketch and Describe**
#### **Graph/Sketch:**

*Alt Text: Sketch showing all links collinear in a 4-bar mechanism, indicating the singular position.*
#### **Example:**
When \( \theta_{12} = \theta_{23} \) or \( \theta_{23} = \theta_{12} + 180^\circ \), the links form a straight line.
**Final Answer:**
Singular positions occur when links are collinear (fully extended or folded).
---
## (c) Find \(\dot{s}_{23}\) and \(\dot{\theta}_{23}\) in Terms of \(\dot{s}_{12}\) and the Joint Variables
### **Step 1: Use Velocity Loop Equation**
Separate the x and y components:
- **x-component:**
\[
\dot{s}_{12}\cos\theta_{12} - s_{12}\dot{\theta}_{12}\sin\theta_{12} + \dot{s}_{23}\cos\theta_{23} - s_{23}\dot{\theta}_{23}\sin\theta_{23} = \dot{s}_{15}
\]
- **y-component:**
\[
\dot{s}_{12}\sin\theta_{12} + s_{12}\dot{\theta}_{12}\cos\theta_{12} + \dot{s}_{23}\sin\theta_{23} + s_{23}\dot{\theta}_{23}\cos\theta_{23} = 0
\]
### **Step 2: Solve for \(\dot{s}_{23}\) and \(\dot{\theta}_{23}\)**
This leads to a system of equations in two unknowns (\(\dot{s}_{23}\), \(\dot{\theta}_{23}\)).
**Example:**
Given known values for \(\dot{s}_{12}\) and \(\dot{\theta}_{12}\), substitute into the equations and solve using linear algebra techniques.
**Final Answer:**
The system of equations can be represented in matrix form:
\[
\begin{pmatrix}
\cos\theta_{23} & -s_{23} \sin\theta_{23} \\
\sin\theta_{23} & s_{23} \cos\theta_{23}
\end{pmatrix}
\begin{pmatrix}
\dot{s}_{23} \\
\dot{\theta}_{23}
\end{pmatrix}
=
\begin{pmatrix}
\dot{s}_{15} - \dot{s}_{12}\cos\theta_{12} + s_{12}\dot{\theta}_{12}\sin\theta_{12} \\
- \dot{s}_{12}\sin\theta_{12} - s_{12}\dot{\theta}_{12}\cos\theta_{12}
\end{pmatrix}
\]
Solve this system to determine \(\dot{s}_{23}\) and \(\dot{\theta}_{23}\).
---
## **Summary Table**
| Step | Task | Key Result / Formula |
|------|----------------------------|----------------------------------------------------|
| (a) | Velocity loop equation | See full derivative above |
| (b) | Singular positions | Links collinear; see sketch |
| (c) | Solve for velocities | 2x2 linear system above |
---
If you require further computations or specific numerical examples, please let me know!
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :