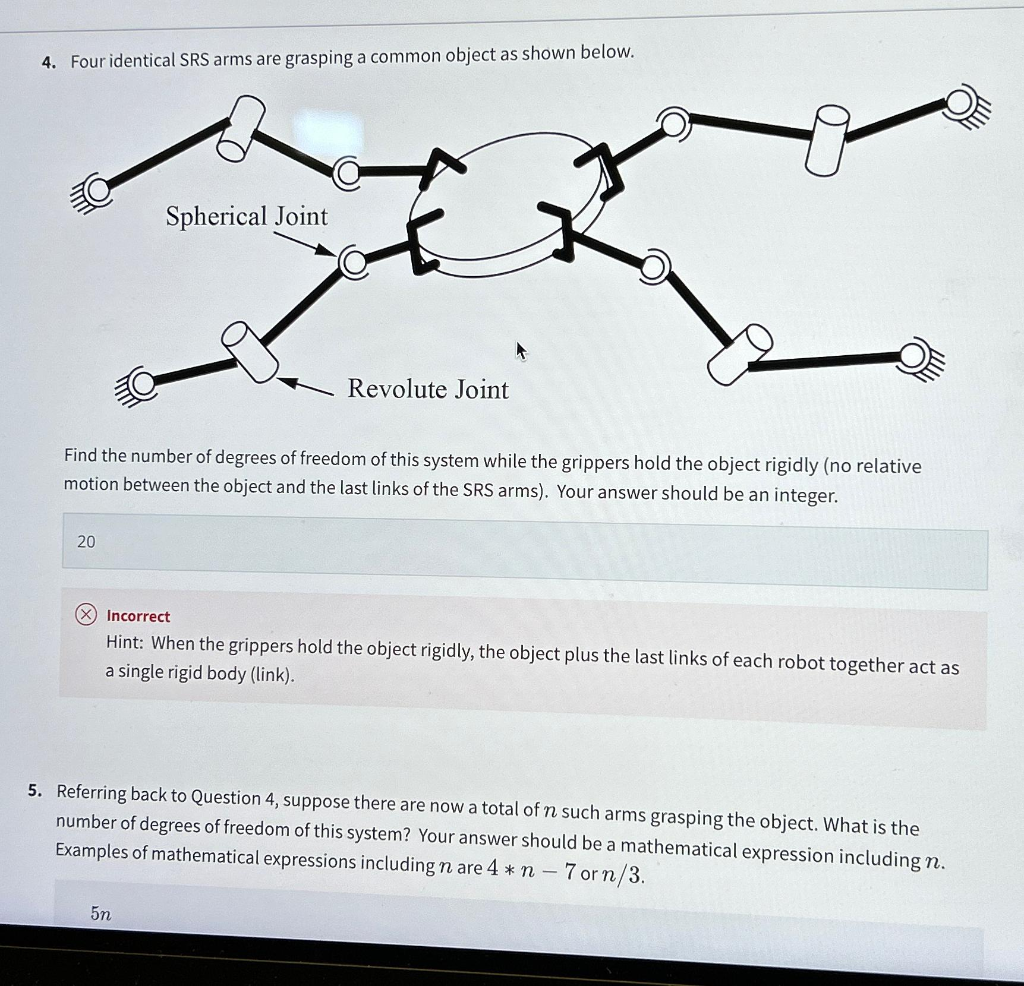
Give step-by-step solution with explanation and final answer:4. Fouridentical SRS arms are grasping a common object as shown below.
Fe, Spherical Joint pri)
Bl | \ ki
Fe, ~~ Revolute Joint
Find the number of degrees of freedom of this system while the grippers hold the object rigidly (no relative
motion between the object and the last links of the SRS arms). Your answer should be an integer.
20
® Incorrect
Hint: When the grippers hold the object rigidly, the object plus the last links of each robot together act as
a single rigid body (link).
5. Re
eferring back to Question 4, suppose there are now a total of such arms grasping the object. What is the
number of degrees of freedom of this system? Your answer should be a mathematical expression i l
: ression includi
Bxamples of mathematical expressions includingn are 4 x n — 7 or n/3. bine
5n
Question:
Give step-by-step solution with explanation and final answer:4. Fouridentical SRS arms are grasping a common object as shown below.
Fe, Spherical Joint pri)
Bl | \ ki
Fe, ~~ Revolute Joint
Find the number of degrees of freedom of this system while the grippers hold the object rigidly (no relative
motion between the object and the last links of the SRS arms). Your answer should be an integer.
20
® Incorrect
Hint: When the grippers hold the object rigidly, the object plus the last links of each robot together act as
a single rigid body (link).
5. Re
eferring back to Question 4, suppose there are now a total of such arms grasping the object. What is the
number of degrees of freedom of this system? Your answer should be a mathematical expression i l
: ression includi
Bxamples of mathematical expressions includingn are 4 x n — 7 or n/3. bine
5n
This is AI generated Response.
Asked by: gvr
Created at: 2025-07-22 22:23:18
Final Answer:
RenderedRaw Text
Did you like this answer?
Let's solve **Question 4** step by step:
### **Step 1: Understanding the System**
- There are 4 identical SRS (Spherical-Revolute-Spherical) arms.
- Each arm **grasps a common object rigidly**.
- **No relative motion** between the object and the last links of the SRS arms.
- The object plus the last links of each robot act as a **single rigid body**.
### **Step 2: Count the Degrees of Freedom (DOF) for Each Arm**
- **Spherical Joint:** 3 DOF (rotation about 3 axes)
- **Revolute Joint:** 1 DOF (rotation about 1 axis)
- **Spherical Joint:** 3 DOF (rotation about 3 axes)
So, each arm has:
\[
\text{DOF per arm} = 3 + 1 + 3 = 7
\]
### **Step 3: Total DOF for All Arms**
There are **4 arms**:
\[
\text{Total DOF (before constraints)} = 4 \times 7 = 28
\]
### **Step 4: Constraints Imposed by the Rigid Grasp**
When all 4 arms grasp the object rigidly, the object and the last links of each arm act as a **single rigid body**.
- A rigid body in 3D space has **6 DOF** (3 translational + 3 rotational).
### **Step 5: Final Degrees of Freedom Calculation**
When the object is grasped rigidly, it acts as one rigid body—**not free to move independently**.
So, the system's degrees of freedom are **reduced to the DOF of a single rigid body**:
\[
\boxed{6}
\]
---
## **Final Answer for Question 4**
\[
\boxed{6}
\]
---
## **Explanation**
- Each SRS arm has 7 DOF.
- 4 arms = 28 DOF.
- When all arms grasp the object rigidly, the object and the last links form a single rigid body: only 6 DOF remain (the possible motions of the whole system as a rigid object).
---
### **Summary Table**
| Step | Calculation | Value |
|-----------------------|-----------------------------------|-------|
| DOF per arm | 3 + 1 + 3 | 7 |
| DOF for 4 arms | 4 × 7 | 28 |
| Rigid body constraint | Degrees of freedom as one body | 6 |
| **Final Answer** | | **6** |
---
If you want the general case for **n arms** (from Question 5), let me know!
VIPSolutions focuses on clear, step‑by‑step explanations so you can learn quickly. Whether you need an AI‑generated walkthrough or a short hint to get unstuck, each solution is organized for fast reading and easy review later.
Search similar questions, compare approaches, and bookmark the best answers for revision. Our goal is simple: quick, reliable study help that feels natural—not noisy.
 VIPSolutions
 4. Fouridentical SRS arms are grasping a common object as shown below.
Fe, Spherical Joint pri)
Bl | \ ki
Fe, ~~ Revolute Joint
Find the number of degrees of freedom of this system while the grippers hold the object rigidly (no relative
motion between the object and the last links of the SRS arms). Your answer should be an integer.
20
® Incorrect
Hint: When the grippers hold the object rigidly, the object plus the last links of each robot together act as
a single rigid body (link).
5. Re
eferring back to Question 4, suppose there are now a total of such arms grasping the object. What is the
number of degrees of freedom of this system? Your answer should be a mathematical expression i l
: ression includi
Bxamples of mathematical expressions includingn are 4 x n — 7 or n/3. bine
5n