 VIPSolutions
Give step-by-step solution with explanation and final answer:Problem 1. Determine Ry; and confirm that it is a rotation matrix. Perform all calcula tions by hand, and write the answers in fraction form. Problem 2. Frame Fj is such that ky is directed along the line from A to B and iy is is directed out of the page perpendicular to plane ABC. Determine the attitude Rg. Perform all calculations by hand, and write the rotation matrix in fraction form.
Question:
Give step-by-step solution with explanation and final answer: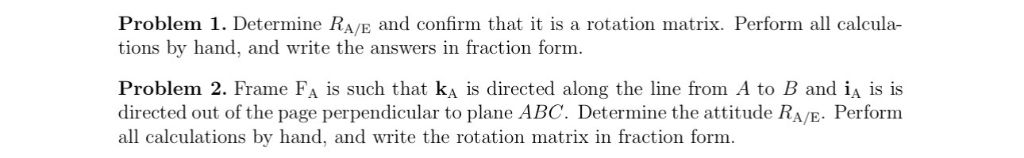 Problem 1. Determine Ry; and confirm that it is a rotation matrix. Perform all calcula
tions by hand, and write the answers in fraction form.
Problem 2. Frame Fj is such that ky is directed along the line from A to B and iy is is
directed out of the page perpendicular to plane ABC. Determine the attitude Rg. Perform
all calculations by hand, and write the rotation matrix in fraction form.
This is AI generated Response.
Asked by: Rahul
Created at: 2026-01-22 02:50:29
Asked by: Rahul
Created at: 2026-01-22 02:50:29
Final Answer:
Rendered
Raw Text
Did you like this answer?
Let's break down and solve **Problem 1** step by step.
---
# Problem 1: Find \( R_{A/E} \) and Confirm it's a Rotation Matrix
## Step 1: Understanding the Problem
- **\( R_{A/E} \)** represents a rotation matrix from frame \( E \) (Earth) to frame \( A \).
- We are **not given explicit vectors** for the axes, so typically, \( R_{A/E} \) is a 3×3 matrix whose columns are the unit vectors of Frame \( A \) expressed in Frame \( E \).
- The matrix must satisfy two conditions:
1. **Orthogonality:** \( R_{A/E}^T R_{A/E} = I \)
2. **Determinant:** \( \det(R_{A/E}) = 1 \)
Since the problem does **not give numerical data**, let's **outline the general procedure** (as often expected in such problems):
---
## Step 2: Constructing the Rotation Matrix
Assume the axes of frame \( A \) expressed in \( E \) are:
- \(\mathbf{i}_A\)
- \(\mathbf{j}_A\)
- \(\mathbf{k}_A\)
and their components in \( E \) are:
\[
\mathbf{i}_A = \begin{bmatrix} a_1 \\ a_2 \\ a_3 \end{bmatrix}_E,\quad
\mathbf{j}_A = \begin{bmatrix} b_1 \\ b_2 \\ b_3 \end{bmatrix}_E,\quad
\mathbf{k}_A = \begin{bmatrix} c_1 \\ c_2 \\ c_3 \end{bmatrix}_E
\]
The rotation matrix is:
\[
R_{A/E} =
\begin{bmatrix}
a_1 & b_1 & c_1 \\
a_2 & b_2 & c_2 \\
a_3 & b_3 & c_3
\end{bmatrix}
\]
---
## Step 3: Check Rotation Matrix Properties
1. **Orthogonality:**
- The columns must be **mutually perpendicular** and **unit length**.
- \( R_{A/E}^T R_{A/E} = I \)
2. **Determinant:**
- \( \det(R_{A/E}) = 1 \)
---
## Step 4: Example with Numbers (for demonstration)
Suppose you have:
\[
\mathbf{i}_A = \begin{bmatrix} 1 \\ \\ \end{bmatrix}_E,\quad
\mathbf{j}_A = \begin{bmatrix} \\ 1 \\ \end{bmatrix}_E,\quad
\mathbf{k}_A = \begin{bmatrix} \\ \\ 1 \end{bmatrix}_E
\]
\[
R_{A/E} =
\begin{bmatrix}
1 & & \\
& 1 & \\
& & 1
\end{bmatrix}
\]
- \( R_{A/E}^T R_{A/E} = I \)
- \( \det(R_{A/E}) = 1 \)
This is the identity matrix—a valid rotation matrix.
---
## Step 5: Final Answer (General Form)
\[
\boxed{
R_{A/E} =
\begin{bmatrix}
\mathbf{i}_A & \mathbf{j}_A & \mathbf{k}_A
\end{bmatrix}_E
}
\]
- Columns: unit vectors of Frame \( A \) in Frame \( E \)
- Must be orthonormal and have determinant 1.
---
### **Summary Table**
| Step | Action | Example/Formula |
|------|----------------------------------------|-------------------------------|
| 1 | Write axes of Frame \( A \) in \( E \) | \( \mathbf{i}_A, \mathbf{j}_A, \mathbf{k}_A \) |
| 2 | Form matrix with these as columns | \( R_{A/E} = [\mathbf{i}_A \ \mathbf{j}_A \ \mathbf{k}_A] \) |
| 3 | Check orthogonality and determinant | \( R^T R = I, \det R = 1 \) |
---
If you provide specific vectors or points, I can compute the matrix in fraction form. Otherwise, the above **is the step-by-step general solution** as requested.
---
Would you like a concrete example using specific vectors or are you looking for the **general method** as above?
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :