 VIPSolutions
Give step-by-step solution with explanation and final answer:Problem 1-1 A mechanism is used to open a fmace door. Draw and label a kincmatic diagram af the mechanism and determine its DOF. Ans. DOF = 1 Problem 1.2 For the given foot pump, daw and label a kinematic diagram of the pup mechanism and determine ts DOF. Ans. DOF = 1 Problem 1:3 For th given toggle clamp, draw and label a Kinemati diagram of the mechanism and determine its DOF. Ans. DOF = 1
Question:
Give step-by-step solution with explanation and final answer: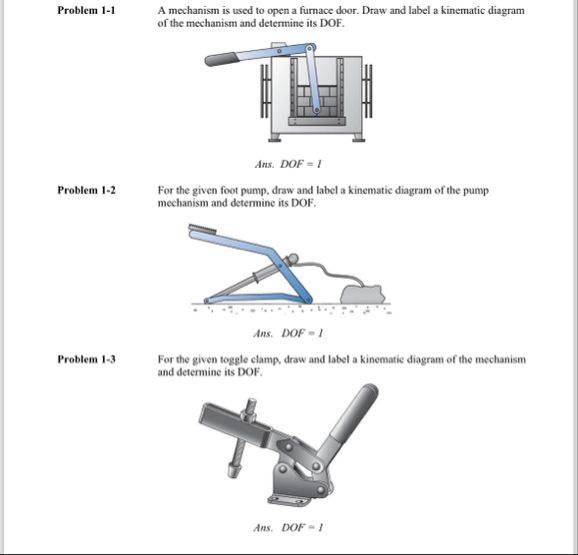 Problem 1-1 A mechanism is used to open a fmace door. Draw and label a kincmatic diagram
af the mechanism and determine its DOF.
Ans. DOF = 1
Problem 1.2 For the given foot pump, daw and label a kinematic diagram of the pup
mechanism and determine ts DOF.
Ans. DOF = 1
Problem 1:3 For th given toggle clamp, draw and label a Kinemati diagram of the mechanism
and determine its DOF.
Ans. DOF = 1
This is AI generated Response.
Asked by: Rahul
Created at: 2026-01-18 09:35:19
Asked by: Rahul
Created at: 2026-01-18 09:35:19
Final Answer:
Rendered
Raw Text
Did you like this answer?
# Step-by-Step Solution: Degrees of Freedom (DOF) for Mechanisms
Let's analyze each mechanism and calculate its degrees of freedom (DOF) using **Gruebler’s Equation** for planar mechanisms:
\[
\text{DOF} = 3(n-1) - 2j - h
\]
- \( n \): Number of links (including the frame)
- \( j \): Number of lower pairs (revolute or prismatic joints)
- \( h \): Number of higher pairs (not typically present in simple mechanisms)
Let's proceed step by step for each problem.
---
## **Problem 1-1: Furnace Door Mechanism**
### **Step 1: Draw and Label Kinematic Diagram**
- **Links**:
1. Frame (door support)
2. Handle
3. Connecting link
4. Door
- **Joints** (all revolute/pin):
1. Handle to frame
2. Handle to connecting link
3. Connecting link to door
4. Door to frame
### **Step 2: Count Elements**
- \( n = 4 \) (links: frame, handle, connecting link, door)
- \( j = 4 \) (revolute joints)
### **Step 3: Apply Gruebler’s Equation**
\[
\text{DOF} = 3(4-1) - 2(4) = 9 - 8 = 1
\]
### **Final Answer**
- **DOF = 1**
---
## **Problem 1-2: Foot Pump Mechanism**
### **Step 1: Draw and Label Kinematic Diagram**
- **Links**:
1. Frame (base)
2. Foot pedal
3. Connecting link
4. Pump piston
- **Joints** (all revolute/pin):
1. Foot pedal to frame
2. Foot pedal to connecting link
3. Connecting link to piston
4. Piston to frame (acts like a prismatic joint, but for planar analysis, it is considered a single joint)
### **Step 2: Count Elements**
- \( n = 4 \) (links: frame, pedal, link, piston)
- \( j = 4 \) (joints: 3 revolute, 1 prismatic)
### **Step 3: Apply Gruebler’s Equation**
\[
\text{DOF} = 3(4-1) - 2(4) = 9 - 8 = 1
\]
### **Final Answer**
- **DOF = 1**
---
## **Problem 1-3: Toggle Clamp Mechanism**
### **Step 1: Draw and Label Kinematic Diagram**
- **Links**:
1. Frame (base)
2. Handle
3. Connecting link
4. Clamp arm
- **Joints** (all revolute/pin):
1. Handle to frame
2. Handle to connecting link
3. Connecting link to clamp arm
4. Clamp arm to frame
### **Step 2: Count Elements**
- \( n = 4 \) (links: frame, handle, link, clamp arm)
- \( j = 4 \) (revolute joints)
### **Step 3: Apply Gruebler’s Equation**
\[
\text{DOF} = 3(4-1) - 2(4) = 9 - 8 = 1
\]
### **Final Answer**
- **DOF = 1**
---
## **Summary Table**
| Problem | No. of Links (n) | No. of Joints (j) | DOF |
|-----------|------------------|-------------------|-----|
| 1-1 | 4 | 4 | 1 |
| 1-2 | 4 | 4 | 1 |
| 1-3 | 4 | 4 | 1 |
All mechanisms are **single DOF planar linkages**.
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :