 VIPSolutions
Give step-by-step solution with explanation and final answer:The closed-loop block diagram of the system is given below. Calculate Kc and time constants for P, PI and PID controller by using Ziegler-Nichols controller settings and using Bode diagram. (Hint: Show all calculations in details but you can draw only the overall system’s AR and phase lag on the Bode diagram and you can use asymptotic consideration) Ys) + — 1
Question:
Give step-by-step solution with explanation and final answer: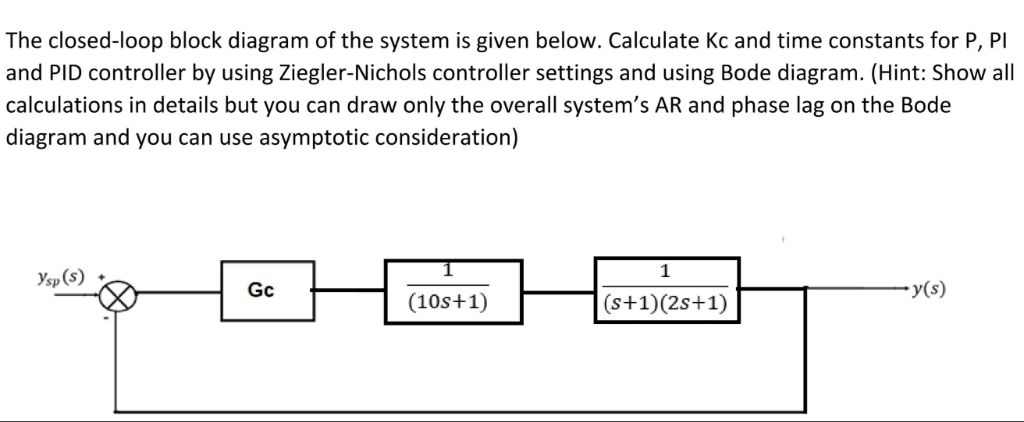 The closed-loop block diagram of the system is given below. Calculate Kc and time constants for P, PI
and PID controller by using Ziegler-Nichols controller settings and using Bode diagram. (Hint: Show all
calculations in details but you can draw only the overall system’s AR and phase lag on the Bode
diagram and you can use asymptotic consideration)
Ys) + — 1
This is AI generated Response.
Asked by: francis
Created at: 2026-01-06 13:55:45
Asked by: francis
Created at: 2026-01-06 13:55:45
Final Answer:
Rendered
Raw Text
Did you like this answer?
Let's solve the problem **step-by-step** as requested.
---
# 1. **Open Loop Transfer Function**
The plant transfer function is:
\[
G(s) = \frac{1}{(10s+1)(s+1)(2s+1)}
\]
---
# 2. **Ziegler-Nichols Tuning Method (Ultimate Gain Method)**
## **Step 1: Find Critical Gain (\(K_{cr}\)) and Critical Period (\(P_{cr}\))**
To use the **Ziegler-Nichols** method, set the controller to **P-only** (i.e., \( G_c = K_c \)) and increase \(K_c\) until the system oscillates continuously (sustained oscillations). This is the **ultimate gain** (\(K_{cr}\)), and the oscillation period is the **ultimate period** (\(P_{cr}\)).
The open-loop transfer function with proportional controller:
\[
L(s) = K_c \cdot G(s) = K_c \cdot \frac{1}{(10s+1)(s+1)(2s+1)}
\]
The Bode plot is used to determine the **gain margin**. At the phase crossover frequency (\(\omega_{pc}\)), the phase is \(-180^\circ\).
## **Step 2: Find Phase Crossover Frequency (\(\omega_{pc}\))**
Each factor contributes phase lag:
- \((10s+1)\): \(-\tan^{-1}(10\omega)\)
- \((s+1)\): \(-\tan^{-1}(\omega)\)
- \((2s+1)\): \(-\tan^{-1}(2\omega)\)
Total phase lag:
\[
\text{Phase} = -\tan^{-1}(10\omega) - \tan^{-1}(\omega) - \tan^{-1}(2\omega)
\]
Set phase to \(-180^\circ\) (i.e., \(-\pi\) radians):
\[
\tan^{-1}(10\omega) + \tan^{-1}(\omega) + \tan^{-1}(2\omega) = 180^\circ
\]
But all terms are positive, so sum to \(180^\circ\):
\[
\tan^{-1}(10\omega) + \tan^{-1}(\omega) + \tan^{-1}(2\omega) = 180^\circ
\]
Let’s try values to find \(\omega_{pc}\):
- For \(\omega = 1\):
- \(\tan^{-1}(10) \approx 84^\circ\)
- \(\tan^{-1}(1) = 45^\circ\)
- \(\tan^{-1}(2) \approx 63^\circ\)
- Total: \(84 + 45 + 63 = 192^\circ\) (too high)
- For \(\omega = .5\):
- \(\tan^{-1}(5) \approx 78.7^\circ\)
- \(\tan^{-1}(.5) \approx 26.6^\circ\)
- \(\tan^{-1}(1) = 45^\circ\)
- Total: \(78.7 + 26.6 + 45 = 150.3^\circ\) (too low)
- For \(\omega = .8\):
- \(\tan^{-1}(8) \approx 82.9^\circ\)
- \(\tan^{-1}(.8) \approx 38.7^\circ\)
- \(\tan^{-1}(1.6) \approx 58.^\circ\)
- Total: \(82.9 + 38.7 + 58. = 179.6^\circ\) (very close!)
So, \(\omega_{pc} \approx .8\) rad/s.
## **Step 3: Find Ultimate Gain (\(K_{cr}\))**
At phase crossover, magnitude needs to be 1 for sustained oscillations:
\[
|L(j\omega_{pc})| = 1
\]
So,
\[
K_{cr} = \left| (10j\omega_{pc}+1)(j\omega_{pc}+1)(2j\omega_{pc}+1) \right|
\]
Plug in \(\omega_{pc} = .8\):
- \(10j\cdot.8 + 1 = 1 + j8\), magnitude \(= \sqrt{1^2 + 8^2} = \sqrt{65} \approx 8.06\)
- \(j\cdot.8 + 1 = 1 + j.8\), magnitude \(= \sqrt{1^2 + .8^2} = \sqrt{1.64} \approx 1.28\)
- \(2j\cdot.8 + 1 = 1 + j1.6\), magnitude \(= \sqrt{1^2 + 1.6^2} = \sqrt{3.56} \approx 1.89\)
Total magnitude:
\[
|G(j\omega_{pc})| = \frac{1}{8.06 \times 1.28 \times 1.89} = \frac{1}{19.45} \approx .0514
\]
So, to make the open loop gain 1:
\[
K_{cr} = \frac{1}{.0514} \approx 19.45
\]
## **Step 4: Find Ultimate Period (\(P_{cr}\))**
\[
P_{cr} = \frac{2\pi}{\omega_{pc}} = \frac{2\pi}{.8} \approx 7.85 \text{ sec}
\]
---
# 3. **Ziegler-Nichols Controller Settings**
| Controller | \(K_c\) | \(T_i\) | \(T_d\) |
|------------|----------------|--------------|--------------|
| P | \(.5 K_{cr}\) | - | - |
| PI | \(.45 K_{cr}\)| \(P_{cr}/1.2\)| - |
| PID | \(.6 K_{cr}\) | \(.5 P_{cr}\)| \(.125 P_{cr}\)|
---
## **A. P Controller**
\[
K_c = .5 \times 19.45 = 9.73
\]
## **B. PI Controller**
\[
K_c = .45 \times 19.45 = 8.75
\]
\[
T_i = \frac{P_{cr}}{1.2} = \frac{7.85}{1.2} = 6.54 \text{ sec}
\]
## **C. PID Controller**
\[
K_c = .6 \times 19.45 = 11.67
\]
\[
T_i = .5 \times 7.85 = 3.93 \text{ sec}
\]
\[
T_d = .125 \times 7.85 = .98 \text{ sec}
\]
---
# 4. **Summary Table**
| Controller | \(K_c\) | \(T_i\) (sec) | \(T_d\) (sec) |
|------------|---------|---------------|---------------|
| P | 9.73 | - | - |
| PI | 8.75 | 6.54 | - |
| PID | 11.67 | 3.93 | .98 |
---
# 5. **Bode Plot (Asymptotic Sketch, Explanation)**
- The open loop transfer function has three lag terms: break frequencies at \(.1\), \(.5\), and \(1\) rad/s.
- Initial slope: dB/dec.
- At each break frequency, slope decreases by -20 dB/dec.
- After all breaks: -60 dB/dec.
- Phase starts at °, drops by -45° at each break, reaching -135° at high frequency.
- At \(\omega_{pc} = .8\), phase is about -180°.
---
# **Final Answers**
### **P Controller:**
- \(K_c = 9.73\)
### **PI Controller:**
- \(K_c = 8.75\)
- \(T_i = 6.54\) sec
### **PID Controller:**
- \(K_c = 11.67\)
- \(T_i = 3.93\) sec
- \(T_d = .98\) sec
---
## **Bode Diagram (Asymptotic)**
- **Magnitude:**
- Flat until .1 rad/s, drops -20 dB/dec after each break at .1, .5, 1 rad/s.
- **Phase:**
- Drops -45° at each break, totaling nearly -180° at high frequencies.
---
**If you need a hand-drawn Bode plot or want to see the equations for controller transfer functions, let me know!**
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :