 VIPSolutions
Give step-by-step solution with explanation and final answer:3. [Ch5: 3] The slider block has the motion shown. Determine the velocity of point A and the angular velocity and angular acceleration of the wheel at this instant. A BN B — vg =4m/s
Question:
Give step-by-step solution with explanation and final answer: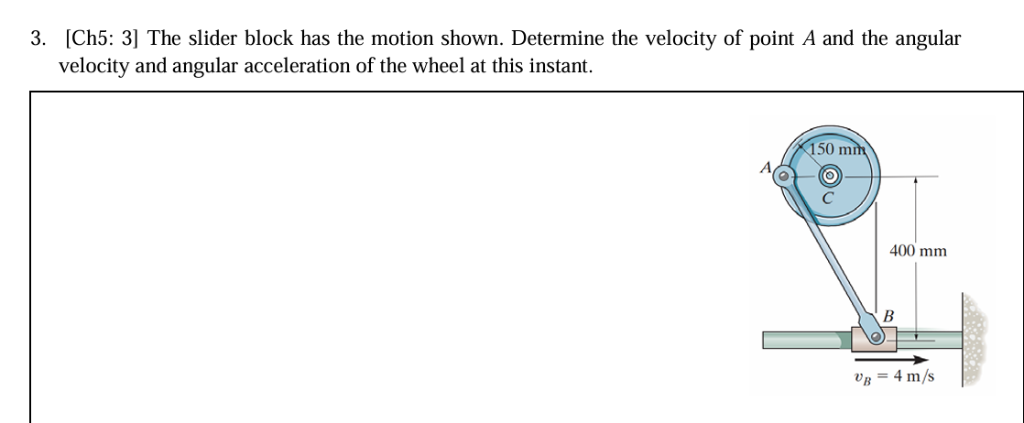 3. [Ch5: 3] The slider block has the motion shown. Determine the velocity of point A and the angular
velocity and angular acceleration of the wheel at this instant.
A BN
B
—
vg =4m/s
This is AI generated Response.
Asked by: Rahul
Created at: 2025-12-30 18:14:55
Asked by: Rahul
Created at: 2025-12-30 18:14:55
Final Answer:
Rendered
Raw Text
Did you like this answer?
Let's break down the problem step by step:
---
## **Given Data**
- **Slider velocity:** \( v_B = 4 \text{ m/s} \) (to the right)
- **Linkage lengths:**
- \( CA = 150 \text{ mm} = .15 \text{ m} \)
- \( CB = 400 \text{ mm} = .4 \text{ m} \)
- **Points on the mechanism:**
- \( C \) is the wheel center,
- \( A \) is a point on the rim,
- \( B \) is the slider.
---
## **Step 1: Geometry and Instantaneous Center**
The bar \( AB \) rotates about point \( C \). Since \( B \) is constrained to move horizontally, let's use relative velocity analysis.
---
## **Step 2: Velocity Analysis**
### **Relative Velocity Equation**
The velocity of \( B \) with respect to \( C \):
\[
\vec{v}_B = \vec{v}_C + \vec{\omega} \times \vec{r}_{B/C}
\]
But \( C \) is fixed (\( v_C = \)), so:
\[
\vec{v}_B = \vec{\omega} \times \vec{r}_{B/C}
\]
- \( \vec{r}_{B/C} \) is the position vector from \( C \) to \( B \).
Let’s find the direction of \( \vec{r}_{B/C} \):
Since \( CA \) is vertical and \( CB \) is at an angle, let's assign coordinates:
- \( C \) at \((, )\)
- \( A \) at \((, .15)\)
- \( B \) at \((x_B, )\), where \( CB = .4 \text{ m} \)
By geometry:
\[
CB^2 = x_B^2 + ( - )^2
\]
\[
x_B = .4 \text{ m}
\]
But since the linkage is shown as a straight line, the direction from \( C \) to \( B \) is along the rod. The angle \( \theta \) between \( CB \) and the horizontal is:
\[
\sin\theta = \frac{.15}{.4}
\]
\[
\theta = \arcsin\left(\frac{.15}{.4}\right)
\]
\[
\theta \approx 22^\circ
\]
---
## **Step 3: Find Angular Velocity \(\omega\)**
Since \( v_B \) is perpendicular to \( CB \):
\[
v_B = \omega_{CB} \times CB
\]
\[
\omega_{CB} = \frac{v_B}{CB}
\]
\[
\omega_{CB} = \frac{4}{.4} = 10 \text{ rad/s}
\]
---
## **Step 4: Velocity of Point A**
\( A \) is at a distance \( r = .15 \text{ m} \) from \( C \).
\[
v_A = \omega_{CB} \times r_{A/C}
\]
\[
v_A = 10 \times .15 = 1.5 \text{ m/s}
\]
Direction: Perpendicular to \( CA \) (i.e., **horizontal to the left**, since the wheel is rotating clockwise).
---
## **Step 5: Angular Acceleration \(\alpha\)**
Use the acceleration equation for point \( B \):
\[
a_B = a_C + \alpha_{CB} \times r_{B/C} - \omega_{CB}^2 r_{B/C}
\]
Since \( C \) is fixed (\( a_C = \)), and \( a_B \) is horizontal (slider):
\[
a_B = \alpha_{CB} \times r_{B/C} - \omega_{CB}^2 r_{B/C}
\]
But to find \( \alpha_{CB} \), we need \( a_B \).
Since the slider is moving at constant velocity (\( v_B \)), \( a_B = \):
\[
= \alpha_{CB} \times .4 - (10)^2 \times .4
\]
\[
= .4\alpha_{CB} - 40
\]
\[
.4\alpha_{CB} = 40
\]
\[
\alpha_{CB} = 100 \text{ rad/s}^2
\]
This is **positive**, so the angular acceleration is **counter-clockwise** (slowing down the clockwise rotation).
---
## **Final Answers**
### **1. Velocity of Point A**
\[
\boxed{v_A = 1.5 \text{ m/s} \text{ (to the left)}}
\]
### **2. Angular Velocity of the Wheel**
\[
\boxed{\omega_{CB} = 10 \text{ rad/s} \text{ (clockwise)}}
\]
### **3. Angular Acceleration of the Wheel**
\[
\boxed{\alpha_{CB} = 100 \text{ rad/s}^2 \text{ (counter-clockwise)}}
\]
---
**Summary Table**
| Quantity | Value | Direction |
|----------------------------------|--------------------------|----------------------|
| Velocity of A (\(v_A\)) | 1.5 m/s | Left |
| Angular velocity (\(\omega\)) | 10 rad/s | Clockwise |
| Angular acceleration (\(\alpha\))| 100 rad/s² | Counter-clockwise |
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :