 VIPSolutions
give answer in 2 step with explanation at the end of each step and final answer at the end:2:49 4 Vol TER ] +56 l (03 ] : vosea atl “ul 2s L.ch m hori @ °3 expert.chegg.com/gna/authoring/ans Chegg ExpertosA Mysolutions 0) Notifications 8 + Student question (© Time Left: 01:59:42 Tag the question Step-by-step Final solution Advanced Physics 1- Consider Example 3.1: Balancing a Pointer in Lecture Sib subjoct 3. Suppose the states of the system are the angular - Search And Selec v position x, (1) = l(t) and the angular velocity x, (t) = (0) of the pointer. Also, let the output y() be the angular position ¢(r) . Assuming the length of the pointer is L = 0.98m and the gravity is ¢ = 9.877, answer the flowing questions a. Is the system fully observable? b. We have previously shown that the system is fully controllable, so, a full state feedback control is feasible. Design an observer feedback system with the closed - loop poles at 1 and -1 and the observer poles at -4 and 4 c. Derive the observer feedback system equations in 1 termsofx=[¥ x, ] ande =x-hat(r) d. Simulate your observer feedback system in MATLAB fortin[ 0 10s |. Assume the initial conditions are: 7 7 K0).e@] =[1 1.5 1 1] e. Compare the results of the observer feedback system against the static feedback system with the same controller gains and initial conditions. a irs ei Denes foc sia of estos po 1d 1 re theca feck pies eatin tres of = 1, 5 sd = 3% ° : °
Question:
give answer in 2 step with explanation at the end of each step and final answer at the end: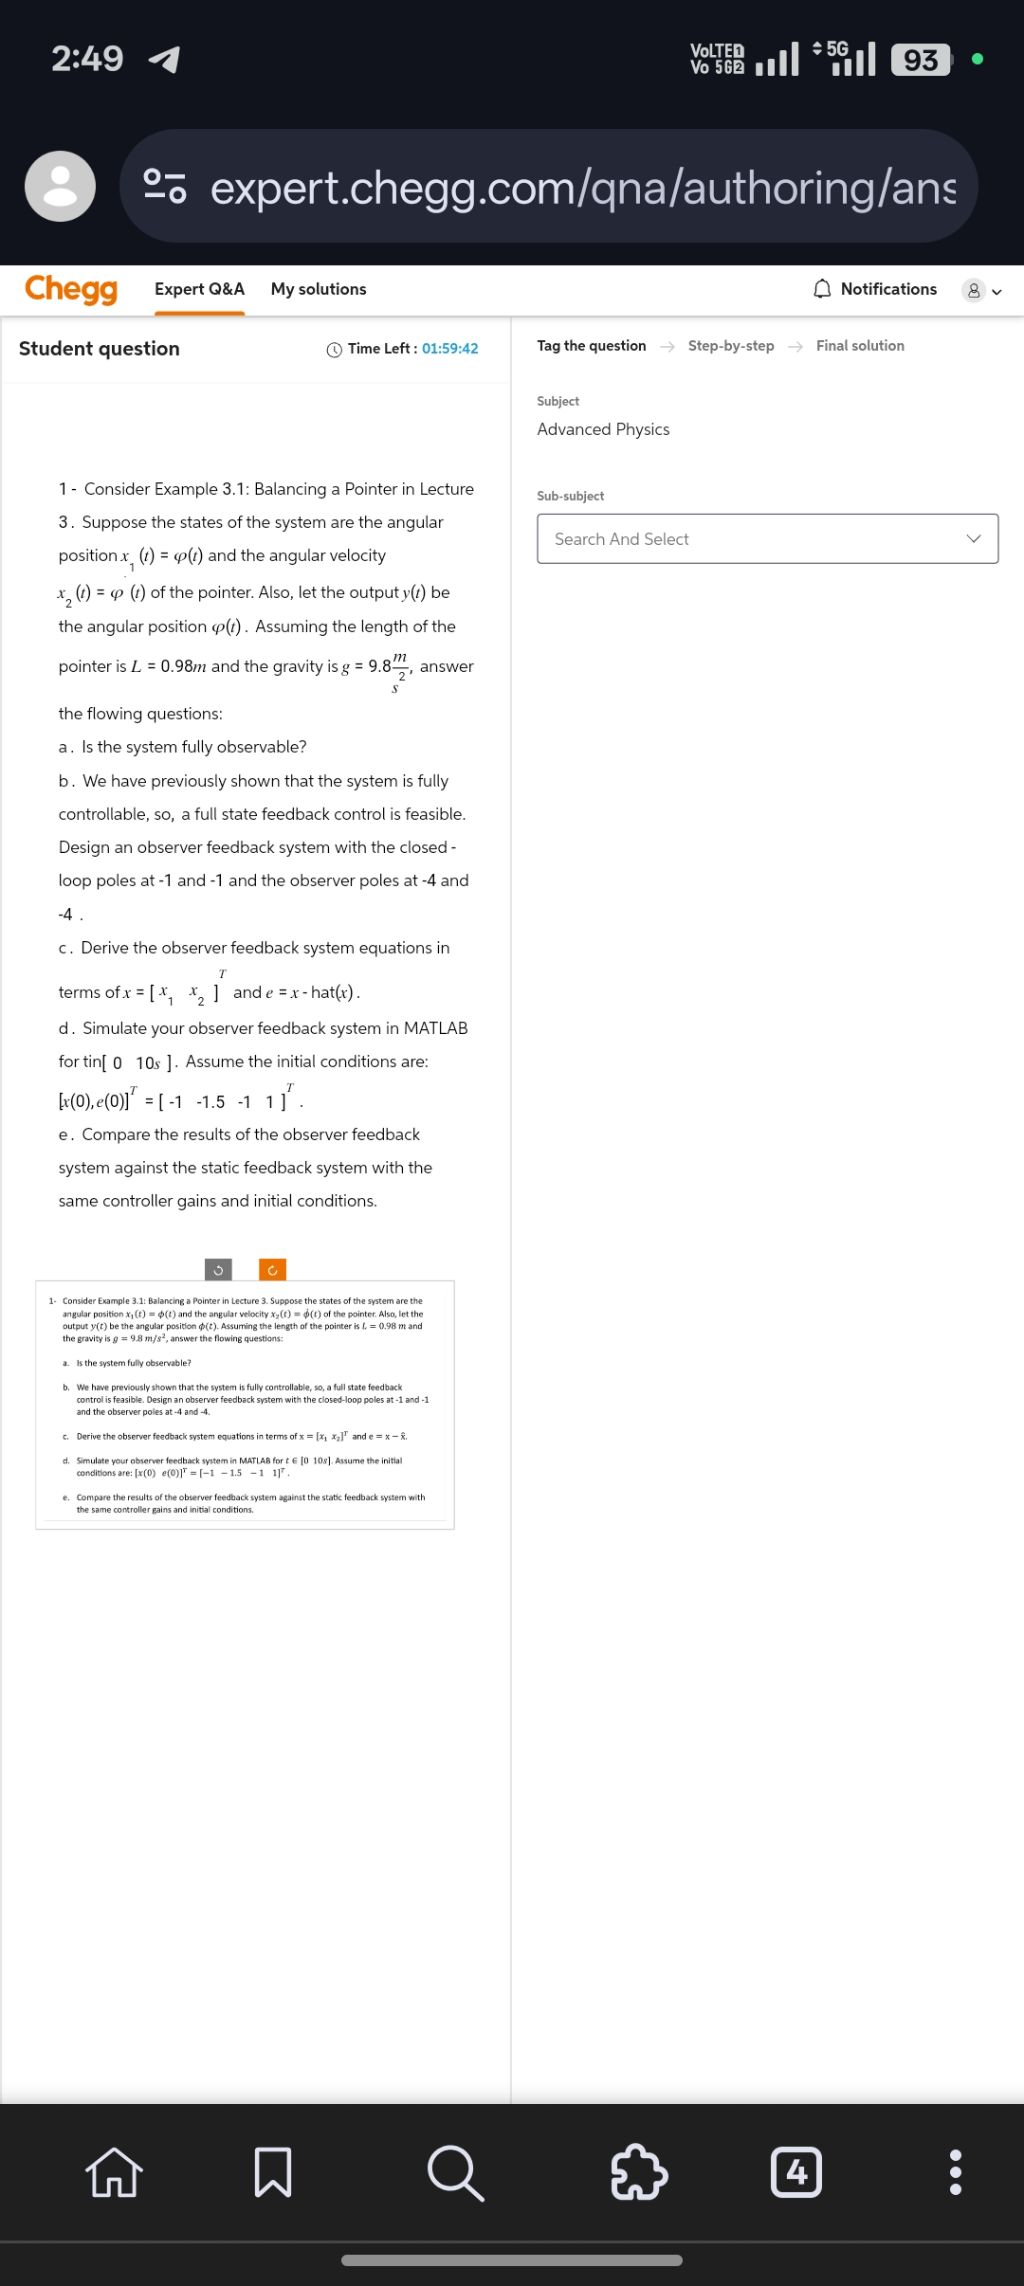 2:49 4 Vol TER ] +56 l (03 ]
: vosea atl “ul
2s L.ch m hori
@ °3 expert.chegg.com/gna/authoring/ans
Chegg ExpertosA Mysolutions 0) Notifications 8 +
Student question (© Time Left: 01:59:42 Tag the question Step-by-step Final solution
Advanced Physics
1- Consider Example 3.1: Balancing a Pointer in Lecture Sib subjoct
3. Suppose the states of the system are the angular -
Search And Selec v
position x, (1) = l(t) and the angular velocity
x, (t) = (0) of the pointer. Also, let the output y() be
the angular position ¢(r) . Assuming the length of the
pointer is L = 0.98m and the gravity is ¢ = 9.877, answer
the flowing questions
a. Is the system fully observable?
b. We have previously shown that the system is fully
controllable, so, a full state feedback control is feasible.
Design an observer feedback system with the closed -
loop poles at 1 and -1 and the observer poles at -4 and
4
c. Derive the observer feedback system equations in
1
termsofx=[¥ x, ] ande =x-hat(r)
d. Simulate your observer feedback system in MATLAB
fortin[ 0 10s |. Assume the initial conditions are:
7 7
K0).e@] =[1 1.5 1 1]
e. Compare the results of the observer feedback
system against the static feedback system with the
same controller gains and initial conditions.
a
irs ei Denes foc sia of estos po 1d 1
re theca feck pies eatin tres of = 1, 5 sd = 3%
°
:
°
Asked by: Rahulkumar
Created at: 2025-10-08 02:51:06
Final Answer:
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :