 VIPSolutions
Act like a helpful tutor and exlain me :Problem 3: 6 points L Atan instance during the calibration process of a coordinate measuring machine, its arms 2 R are in the position shown. For known lengths L,, L,, L, and for variable angles 8, & 6, write down the position vector denoting the tip R with respect to the origin 0. [A 2 iy Your answer should be of the form 7p = ( + ( )ft,.. where fi, and fi,, are t unit vectors shown in the figure. L 8, & Co AL
Question:
Act like a helpful tutor and exlain me :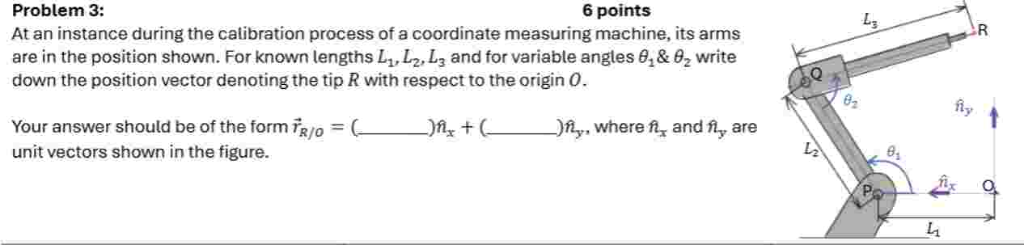 Problem 3: 6 points L
Atan instance during the calibration process of a coordinate measuring machine, its arms 2 R
are in the position shown. For known lengths L,, L,, L, and for variable angles 8, & 6, write
down the position vector denoting the tip R with respect to the origin 0.
[A
2 iy
Your answer should be of the form 7p = ( + ( )ft,.. where fi, and fi,, are t
unit vectors shown in the figure. L 8,
&
Co AL
This is AI generated Response.
Asked by: Alok Kumar
Created at: 2026-01-25 06:43:20
Asked by: Alok Kumar
Created at: 2026-01-25 06:43:20
Final Answer:
Rendered
Raw Text
Did you like this answer?
# Explanation of Problem 3
Let's break down the problem step by step!
---
## **Given:**
- **Lengths:** \( L_1, L_2, L_3 \)
- **Angles:** \( \theta_1, \theta_2 \)
- **Task:** Find the position vector of tip \( R \) with respect to the origin \( O \).
- **Form:** \( \vec{r}_{R/O} = (\text{_____})\hat{n}_x + (\text{_____})\hat{n}_y \)
---
## **Step-by-Step Solution**
### **1. Analyzing the Mechanism**
- **First Link:** From \( O \) to \( P \) of length \( L_1 \) along \( \hat{n}_x \).
- **Second Link:** From \( P \) to \( Q \) of length \( L_2 \) at angle \( \theta_1 \) from \( \hat{n}_x \).
- **Third Link:** From \( Q \) to \( R \) of length \( L_3 \) at angle \( \theta_1 + \theta_2 \) from \( \hat{n}_x \).
### **2. Writing Each Vector**
#### **From \( O \) to \( P \):**
\[
\vec{r}_{P/O} = L_1 \hat{n}_x
\]
#### **From \( P \) to \( Q \):**
\[
\vec{r}_{Q/P} = L_2 (\cos\theta_1 \hat{n}_x + \sin\theta_1 \hat{n}_y)
\]
#### **From \( Q \) to \( R \):**
\[
\vec{r}_{R/Q} = L_3 \left[\cos(\theta_1 + \theta_2) \hat{n}_x + \sin(\theta_1 + \theta_2) \hat{n}_y \right]
\]
### **3. Total Position Vector \( \vec{r}_{R/O} \):**
Add up all vectors:
\[
\vec{r}_{R/O} = \vec{r}_{P/O} + \vec{r}_{Q/P} + \vec{r}_{R/Q}
\]
Substitute the expressions:
\[
\begin{align*}
\vec{r}_{R/O} = &\ L_1 \hat{n}_x \\
&+ L_2 (\cos\theta_1 \hat{n}_x + \sin\theta_1 \hat{n}_y) \\
&+ L_3 [\cos(\theta_1 + \theta_2) \hat{n}_x + \sin(\theta_1 + \theta_2) \hat{n}_y]
\end{align*}
\]
---
### **4. Combine \( \hat{n}_x \) and \( \hat{n}_y \) Terms:**
**For \( \hat{n}_x \):**
\[
L_1 + L_2\cos\theta_1 + L_3\cos(\theta_1 + \theta_2)
\]
**For \( \hat{n}_y \):**
\[
L_2\sin\theta_1 + L_3\sin(\theta_1 + \theta_2)
\]
---
## **Final Answer**
\[
\boxed{
\vec{r}_{R/O} = \left[ L_1 + L_2\cos\theta_1 + L_3\cos(\theta_1 + \theta_2)\right] \hat{n}_x
+ \left[ L_2\sin\theta_1 + L_3\sin(\theta_1 + \theta_2)\right] \hat{n}_y
}
\]
---
### **Summary Table**
| Link | \( x \)-component | \( y \)-component |
|-------------------|------------------------------------------------|------------------------------------------------|
| \( O \to P \) | \( L_1 \) | |
| \( P \to Q \) | \( L_2\cos\theta_1 \) | \( L_2\sin\theta_1 \) |
| \( Q \to R \) | \( L_3\cos(\theta_1 + \theta_2) \) | \( L_3\sin(\theta_1 + \theta_2) \) |
---
## **Let me know if you need a step-by-step diagram or further explanation on any part!**
Question:
pls provide solution in details with correct equation format pls
This is AI generated Response.
Asked by: Alok Kumar
Created at: 2026-01-25 06:45:56
Asked by: Alok Kumar
Created at: 2026-01-25 06:45:56
Final Answer:
Rendered
Raw Text
Did you like this answer?
# Detailed Solution for Problem 3
## **Overview**
In this problem, we need to find the position vector of point \( R \) with respect to the origin \( O \) for a coordinate measuring machine with known arm lengths \( L_1, L_2, L_3 \) and variable angles \( \theta_1 \) and \( \theta_2 \).
### **Required Form**
The answer should be in the form:
\[
\vec{r}_{R/O} = (x) \hat{n}_x + (y) \hat{n}_y
\]
## **Step 1: Analyze the Structure**
1. **Link from \( O \) to \( P \)**:
- Length: \( L_1 \)
- Direction: Along \( \hat{n}_x \)
2. **Link from \( P \) to \( Q \)**:
- Length: \( L_2 \)
- Direction: At angle \( \theta_1 \)
3. **Link from \( Q \) to \( R \)**:
- Length: \( L_3 \)
- Direction: At angle \( \theta_1 + \theta_2 \)
## **Step 2: Write Position Vectors**
### **1. From \( O \) to \( P \)**
\[
\vec{r}_{P/O} = L_1 \hat{n}_x
\]
### **2. From \( P \) to \( Q \)**
\[
\vec{r}_{Q/P} = L_2 \left( \cos \theta_1 \hat{n}_x + \sin \theta_1 \hat{n}_y \right)
\]
### **3. From \( Q \) to \( R \)**
\[
\vec{r}_{R/Q} = L_3 \left( \cos(\theta_1 + \theta_2) \hat{n}_x + \sin(\theta_1 + \theta_2) \hat{n}_y \right)
\]
## **Step 3: Combine the Vectors**
To find the total position vector \( \vec{r}_{R/O} \), we sum all the position vectors:
\[
\vec{r}_{R/O} = \vec{r}_{P/O} + \vec{r}_{Q/P} + \vec{r}_{R/Q}
\]
Substituting the components:
\[
\begin{align*}
\vec{r}_{R/O} = &\ L_1 \hat{n}_x \\
&+ L_2 \left( \cos \theta_1 \hat{n}_x + \sin \theta_1 \hat{n}_y \right) \\
&+ L_3 \left( \cos(\theta_1 + \theta_2) \hat{n}_x + \sin(\theta_1 + \theta_2) \hat{n}_y \right)
\end{align*}
\]
## **Step 4: Rearranging Terms**
### **Combine \( \hat{n}_x \) Components:**
\[
x = L_1 + L_2 \cos \theta_1 + L_3 \cos(\theta_1 + \theta_2)
\]
### **Combine \( \hat{n}_y \) Components:**
\[
y = L_2 \sin \theta_1 + L_3 \sin(\theta_1 + \theta_2)
\]
## **Final Position Vector**
Combining the components, we have:
\[
\vec{r}_{R/O} = \left( L_1 + L_2 \cos \theta_1 + L_3 \cos(\theta_1 + \theta_2) \right) \hat{n}_x + \left( L_2 \sin \theta_1 + L_3 \sin(\theta_1 + \theta_2) \right) \hat{n}_y
\]
## **Summary**
The final position vector denoting the tip \( R \) with respect to the origin \( O \) is:
\[
\boxed{
\vec{r}_{R/O} = \left( L_1 + L_2 \cos \theta_1 + L_3 \cos(\theta_1 + \theta_2) \right) \hat{n}_x + \left( L_2 \sin \theta_1 + L_3 \sin(\theta_1 + \theta_2) \right) \hat{n}_y
}
\]
This vector describes the location of point \( R \) based on the lengths of the arms and angles of rotation. Let me know if you need further clarification or additional examples!
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :