 VIPSolutions
Act like a helpful tutor and exlain me : Calculate the mobility of the given linkage¥ | 57.460 pu | 15665° 126.58 a 90.00° ANY APNE 5 a [al fh NOT — =e ~ 5 (0 a4-1270 - J%4 5-120 ( BC=2032 J 35.000 D=3810 a OE=1136 25° BE=1016 L 00-635
Question:
Act like a helpful tutor and exlain me :
Calculate the mobility of the given linkage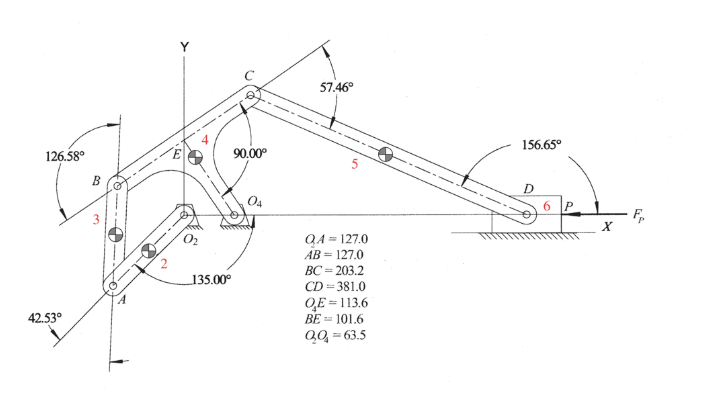 ¥
| 57.460
pu | 15665°
126.58 a 90.00° ANY
APNE
5 a [al
fh NOT — =e ~ 5
(0 a4-1270 -
J%4 5-120
( BC=2032
J 35.000 D=3810
a OE=1136
25° BE=1016
L 00-635
This is AI generated Response.
Asked by: manish kumar
Created at: 2025-09-10 06:51:19
Asked by: manish kumar
Created at: 2025-09-10 06:51:19
Final Answer:
Rendered
Raw Text
Did you like this answer?
# Calculating the Mobility (Degrees of Freedom) of the Linkage
Let's break down the process **step by step**.
---
## **Step 1: Identify the Mechanism Type**
This is a **planar mechanism** (all motion is in a single plane).
---
## **Step 2: Count the Number of Links (L)**
- Each rigid body is a **link**.
- Include the **frame** (ground) as one link.
### **From the diagram:**
Let's number the links as marked:
1. Frame (ground)
2. Link 2
3. Link 3
4. Link 4
5. Link 5
6. Link 6
**Total Links, L = 6**
---
## **Step 3: Count the Number of Joints (J)**
- Each **pin (revolute)** or **sliding (prismatic)** joint counts as 1.
- Only count joints that connect two links.
### **From the diagram:**
Let's list the joints (marked by circles):
- O2 (pin joint)
- A (pin joint)
- B (pin joint)
- E (pin joint)
- O4 (pin joint)
- C (pin joint)
- D (pin joint)
- P (pin joint)
**Total Joints, J = 8**
---
## **Step 4: Use Gruebler’s Equation (Planar Mechanisms)**
The general equation for planar mechanisms is:
\[
M = 3(L - 1) - 2J
\]
where:
- \( M \) = Mobility (degrees of freedom)
- \( L \) = Number of links
- \( J \) = Number of lower pairs (single-dof joints; here, all are revolute)
---
## **Step 5: Plug in the Numbers**
Substitute the counted values:
\[
M = 3(6 - 1) - 2 \times 8
\]
\[
M = 3 \times 5 - 16
\]
\[
M = 15 - 16
\]
\[
M = -1
\]
---
## **Step 6: Interpretation**
- **M = -1** means the mechanism is **over-constrained** (a structure, not a mechanism), or there could be a counting error (e.g., redundant links or joints).
- Sometimes, additional constraints (such as fixed sliders) or special cases (coincident joints) can affect the count.
### **Double-check:**
- Are any links *grounded* twice (e.g., two fixed pivots on the same link)?
- Are there redundant or multiple joints at a single location?
---
## **Summary Table**
| Item | Count |
|-----------------|-------|
| Links (L) | 6 |
| Joints (J) | 8 |
| Mobility (M) | -1 |
---
## **Conclusion**
> **The calculated mobility using the basic Gruebler equation is -1, indicating a structure rather than a mechanism. Review the actual physical connections to check for redundant constraints or special cases, or provide more details if possible!**
---
### **Questions?**
If you want to analyze a specific part of the mechanism or need more details, let me know!
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :