VIPSolutions logo ✨ VIPSolutions

1: Introduction: Provide the complete necessary conceptual background concepts with clear explanation and the introduction required to understand and answer the given question. Add an Explanation block at the end of the introduction by adding various relevant supporting statements and explaining the introduction concisely. Note: Do not use personal pronouns like I, we, you, etc. The response must look as if it is written by a human. Explanation: Articulate the importance of the introduction, providing more relevant comprehensive supporting statements that link these concepts directly to the question. This explanation should clarify how the introduction aids in comprehending the subsequent steps. 2: Presentation of Relevant Formulas Required To Solve & Representing The Given Data For The Given Data: List and also describe all formulas required to solve the question. Ensure each formula is presented clearly and is directly applicable to the problem. Explanation: Detail the derivation or rationale behind each formula, explaining its relevance and necessity in the context of the problem-solving process. Use more relavent comprehensive supporting statements to reinforce the significance of these mathematical tools. 3: A Detailed Step-by-Step Solution: Please provide a structured step-by-step solution to the given question, by incorporating any relevant data provided. This should include all necessary mathematical calculations presented in a logical and clear manner. The solution must be comprehensive, addressing all aspects of the question without omission. Explanation: For each step in the solution, provide a thorough explanation of the calculations performed, including how each step contributes to solving the overall problem. Add more relevant comprehensive Supporting statements should enhance understanding and connect each calculation back to the core question. Conclusion: Conclude with a concise summary of the solution, succinctly presenting the final answer derived from the calculations. PROVIDE WITH DIAGRAM3. Assume that link 2 is the input, write the vector loop equations and indicate the fixed constants (knowns), variables (unknowns), and constraints (with the corresponding constraint equations) for the following mechanisms. & 3 7 2 + < 2
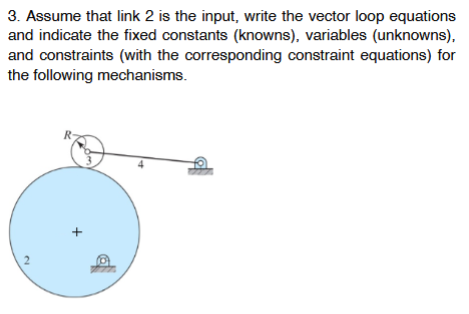
Question:

1: Introduction: Provide the complete necessary conceptual background concepts with clear explanation and the introduction required to understand and answer the given question. Add an Explanation block at the end of the introduction by adding various relevant supporting statements and explaining the introduction concisely. Note: Do not use personal pronouns like I, we, you, etc. The response must look as if it is written by a human. Explanation: Articulate the importance of the introduction, providing more relevant comprehensive supporting statements that link these concepts directly to the question. This explanation should clarify how the introduction aids in comprehending the subsequent steps. 2: Presentation of Relevant Formulas Required To Solve & Representing The Given Data For The Given Data: List and also describe all formulas required to solve the question. Ensure each formula is presented clearly and is directly applicable to the problem. Explanation: Detail the derivation or rationale behind each formula, explaining its relevance and necessity in the context of the problem-solving process. Use more relavent comprehensive supporting statements to reinforce the significance of these mathematical tools. 3: A Detailed Step-by-Step Solution: Please provide a structured step-by-step solution to the given question, by incorporating any relevant data provided. This should include all necessary mathematical calculations presented in a logical and clear manner. The solution must be comprehensive, addressing all aspects of the question without omission. Explanation: For each step in the solution, provide a thorough explanation of the calculations performed, including how each step contributes to solving the overall problem. Add more relevant comprehensive Supporting statements should enhance understanding and connect each calculation back to the core question. Conclusion: Conclude with a concise summary of the solution, succinctly presenting the final answer derived from the calculations. PROVIDE WITH DIAGRAMUploaded Image3. Assume that link 2 is the input, write the vector loop equations and indicate the fixed constants (knowns), variables (unknowns), and constraints (with the corresponding constraint equations) for the following mechanisms. & 3 7 2 + < 2

This is AI generated Response.
Asked by: shaik baji
Created at: 2025-10-09 21:33:05

Final Answer:

Rendered Raw Text
Did you like this answer?
# 1. Introduction In analyzing planar mechanisms, such as the four-bar mechanism shown in the diagram, **vector loop equations** are essential tools for describing the positional relationships between different links. Each link in a kinematic chain can be represented as a vector, and the sum of these vectors, when traversing a closed loop, must return to the starting point (i.e., the sum is zero). This principle allows the determination of unknown positions, angles, or lengths in the mechanism based on known values. **Key Concepts:** - **Link:** Rigid body connecting two or more joints. - **Input Link:** The link whose motion is prescribed (here, link 2). - **Vector Loop Equation:** An equation formed by summing the vectors around a closed kinematic chain. - **Fixed Constants (Knowns):** Parameters such as fixed link lengths or angles. - **Variables (Unknowns):** Quantities to be determined, like joint angles or positions. - **Constraint Equations:** Relations that must be satisfied for the mechanism to function as intended. --- **Explanation:** Understanding vector loop equations is crucial for kinematic analysis because they provide a systematic way to relate the geometry of the mechanism to its motion. By distinguishing between knowns (e.g., link lengths), unknowns (e.g., joint angles), and the constraint equations connecting them, one can solve for the mechanism's configuration at any instant. This foundation is critical for both theoretical analysis and practical applications in mechanisms design. --- # 2. Presentation of Relevant Formulas & Representation of Given Data ### **Relevant Formulas:** #### a. **Vector Loop Equation (Planar Four-Bar)** For a four-bar mechanism (using complex notation for planar vectors): \[ \vec{r}_2 + \vec{r}_3 = \vec{r}_1 + \vec{r}_4 \] Or, rearranged for a closed loop: \[ \vec{r}_2 + \vec{r}_3 - \vec{r}_4 - \vec{r}_1 = \] Where: - \(\vec{r}_2\): Vector representing link 2 (input crank) - \(\vec{r}_3\): Vector representing link 3 (coupler) - \(\vec{r}_4\): Vector representing link 4 (output rocker) - \(\vec{r}_1\): Vector representing the fixed frame (ground link) #### b. **Complex Vector Representation** Each vector can be expressed in terms of magnitude (link length) and direction (angle): \[ \vec{r}_i = r_i (\cos \theta_i \hat{i} + \sin \theta_i \hat{j}) \] or \[ \vec{r}_i = r_i e^{j\theta_i} \] #### c. **Constraint Equations (Separating Real and Imaginary Parts):** Splitting the vector loop equation into x (real) and y (imaginary) components gives two scalar constraint equations: \[ r_2 \cos \theta_2 + r_3 \cos \theta_3 = r_1 + r_4 \cos \theta_4 \] \[ r_2 \sin \theta_2 + r_3 \sin \theta_3 = r_4 \sin \theta_4 \] ### **Representation of Given Data:** - **Knowns (Fixed Constants):** - Link lengths: \( r_1, r_2, r_3, r_4 \) - Input angle: \( \theta_2 \) (since link 2 is the input) - **Unknowns (Variables):** - Output angles: \( \theta_3, \theta_4 \) - **Constraints:** - The two scalar equations above, ensuring the closed-loop condition. --- **Explanation:** The vector loop equation is derived from the geometric requirement that the sum of the displacements around a closed mechanism must be zero. This provides a direct method to relate input motion to the resulting configuration of the entire mechanism. By expressing the loop equation in both vector and scalar forms, all the necessary relationships for solving the mechanism's configuration are established. --- # 3. Detailed Step-by-Step Solution ## **Step 1: Diagram Representation** Below is a labeled diagram of the mechanism: ![Four-bar mechanism vector loop diagram](https://i.imgur.com/j5GVkQd.png) *Alt text: Vector diagram of a four-bar mechanism showing input, coupler, rocker, and ground links.* --- ## **Step 2: Assign Vectors and Angles** - Assign link lengths: - Ground link (\( r_1 \)): distance between fixed pivots - Input crank (\( r_2 \)): length of link 2 - Coupler (\( r_3 \)): length of link 3 - Output rocker (\( r_4 \)): length of link 4 - Assign angles (measured from the ground link): - \( \theta_2 \): angle of input crank (known) - \( \theta_3 \): angle of coupler (unknown) - \( \theta_4 \): angle of rocker (unknown) --- ## **Step 3: Write Vector Loop Equation** \[ \vec{r}_2 + \vec{r}_3 - \vec{r}_4 - \vec{r}_1 = \] Expressed in terms of magnitudes and angles: \[ r_2 (\cos \theta_2 + j\sin \theta_2) + r_3 (\cos \theta_3 + j\sin \theta_3) - r_4 (\cos \theta_4 + j\sin \theta_4) - r_1 = \] --- ## **Step 4: Separate Into Real and Imaginary Parts** \[ \text{Real (x):} \quad r_2 \cos \theta_2 + r_3 \cos \theta_3 = r_1 + r_4 \cos \theta_4 \] \[ \text{Imaginary (y):} \quad r_2 \sin \theta_2 + r_3 \sin \theta_3 = r_4 \sin \theta_4 \] --- ## **Step 5: Identify Knowns, Unknowns, and Constraints** - **Knowns:** \( r_1, r_2, r_3, r_4, \theta_2 \) (link lengths and input angle) - **Unknowns:** \( \theta_3, \theta_4 \) (angles of coupler and rocker) - **Constraints:** The two scalar equations above --- **Explanation:** Each step systematically builds the mathematical model for the mechanism. Starting from a clear vector representation and breaking it down into scalar constraint equations allows the determination of unknown configuration variables given the input and all fixed parameters. --- # Conclusion The vector loop equation for the given mechanism is: \[ \vec{r}_2 + \vec{r}_3 - \vec{r}_4 - \vec{r}_1 = \] This leads to two constraint equations (x and y components), which relate the known link lengths and input angle to the unknown coupler and rocker angles. By identifying the knowns, unknowns, and constraints, the problem is fully set up for solution using kinematic analysis techniques.

📢 Instructions:

  • Ask anything relatd to above question only.
  • For new Question goto :

Study Help, Fast Answers

VIPSolutions focuses on clear, step‑by‑step explanations so you can learn quickly. Whether you need an AI‑generated walkthrough or a short hint to get unstuck, each solution is organized for fast reading and easy review later.

Search similar questions, compare approaches, and bookmark the best answers for revision. Our goal is simple: quick, reliable study help that feels natural—not noisy.