 VIPSolutions
Chegg ewmoms mysautions 2 Ncstons + Student question EE FE) [J] [A c [5 Bi 5 _— 3 Ra X spa [1] 04 Start Solving. JI . CF = Qs cuEoOoOE ABOBO@ Neem, lie
Question:
 Chegg ewmoms mysautions 2 Ncstons +
Student question EE
FE)
[J]
[A c
[5
Bi 5
_— 3
Ra X
spa
[1] 04
Start Solving. JI .
CF = Qs cuEoOoOE ABOBO@ Neem, lie
This is AI generated Response.
Asked by: kasireddi sai
Created at: 2025-10-18 17:16:06
Asked by: kasireddi sai
Created at: 2025-10-18 17:16:06
Final Answer:
Rendered
Raw Text
Did you like this answer?
# Problem Analysis
**Given:**
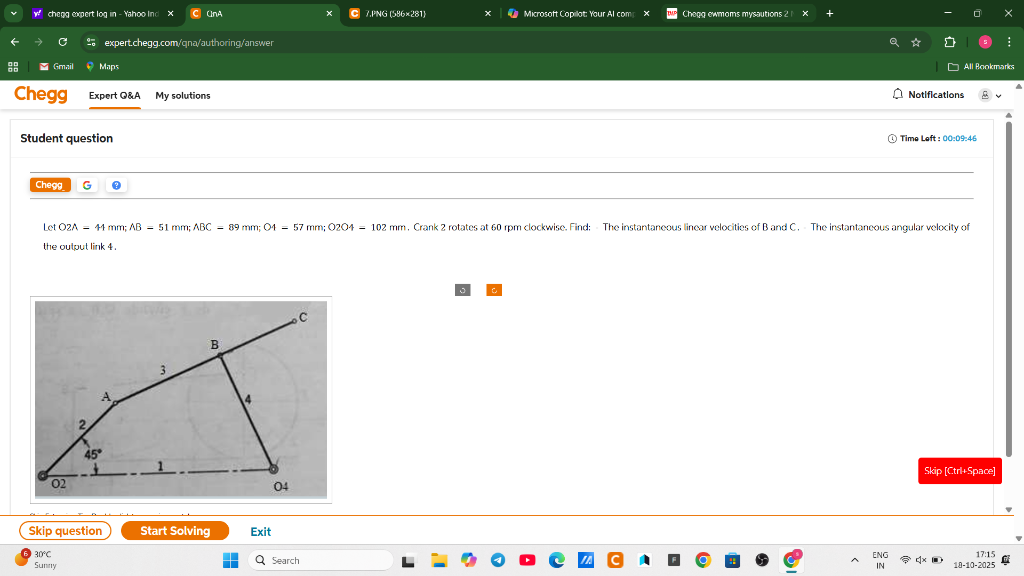
- \( O_2A = 44\ \text{mm} \)
- \( AB = 51\ \text{mm} \)
- \( BC = 89\ \text{mm} \)
- \( O_4 = 57\ \text{mm} \)
- \( O_2O_4 = 102\ \text{mm} \)
- Crank 2 (\( O_2A \)) rotates at \( 60\ \text{rpm} \) **clockwise**
**To Find:**
1. Instantaneous linear velocities of **points B and C**
2. Instantaneous angular velocity of the **output link 4**
---
## Step 1: Angular Velocity of Crank 2
\[
\omega_2 = 2\pi N = 2\pi \times \frac{60}{60} = 2\pi\ \text{rad/s}
\]
---
## Step 2: Linear Velocity of A
\[
v_A = \omega_2 \times O_2A = 2\pi \times .044 = .2764\ \text{m/s}
\]
---
## Step 3: Velocity Diagram (Method Overview)
Because this is a four-bar mechanism, velocities can be found using:
- Instantaneous Center of Rotation (ICR) method
- Relative velocity method
### Key Points:
- \( O_2 \) is fixed: \( v_{O_2} = \)
- \( A \) moves perpendicular to \( O_2A \) with \( v_A \)
- \( B \) moves perpendicular to \( AB \)
- \( C \) moves perpendicular to \( BC \)
- \( O_4 \) is fixed: \( v_{O_4} = \)
---
## Step 4: Relative Velocity Equations
1. **For link AB:**
\[
v_B = v_A + v_{B/A}
\]
Where \( v_{B/A} \) is perpendicular to \( AB \).
2. **For link BC:**
\[
v_C = v_B + v_{C/B}
\]
Where \( v_{C/B} \) is perpendicular to \( BC \).
---
## Step 5: Find Angular Velocity of Output Link 4
Let \( \omega_4 \) be the angular velocity of the output link.
\[
v_C = \omega_4 \times O_4C
\]
---
## Step 6: Final Steps
1. **Draw the configuration to scale or use vector equations.**
2. **Use geometry or trigonometry to resolve the velocities.**
---
## Summary Table
| Parameter | Value/Formula |
|---------------------|-----------------------------------|
| Angular velocity, \( \omega_2 \) | \( 2\pi\ \text{rad/s} \) |
| Linear velocity, \( v_A \) | \( .2764\ \text{m/s} \) |
| Velocities of B, C | From vector geometry |
| Angular velocity, \( \omega_4 \) | \( \frac{v_C}{O_4C} \) |
---
## **You Need:**
- To either draw the velocity diagram to scale, or
- Use a software or analytical method to solve the velocity polygons.
---
### **If you provide the angle positions or a clear vector diagram, I can help you step-by-step with the vector math.**
---
### **Let me know if you want the step-by-step solution using the relative velocity method or if you want a graphical approach!**
📢 Instructions:
- Ask anything relatd to above question only.
- For new Question goto :